|
Sooyoung Ryu I am a senior undergraduate at Seoul National University, currently collaborating remotely with researchers at Stanford University on robot memory. Previously, as an exchange student at EPFL, I worked with Prof. Mathieu Salzmann at EPFL CVLab on diffusion model quantization. My research focuses on robot learning, particularly long-horizon planning, self-improvement, and world models. I aim to build general-purpose embodied agents that learn from experience, adapt to new environments, and acquire new skills while retaining prior knowledge. I am seeking Ph.D. opportunities starting in Fall 2027. I would be happy to discuss research opportunities or potential collaborations—please get in touch. Email / GitHub / X / LinkedIn / Google Scholar |
|
Research |
|
MEMI: Reverse-Engineering What Robots Should Remember
Sooyoung Ryu, Yinpei Dai, Yilun Du, Chelsea Finn, Yuejiang Liu Research blog, 2026 project page / code / leaderboard MEMI learns what robots should remember by reasoning backward from demonstrations, then improves memory and policy prompts through feedback. |
|
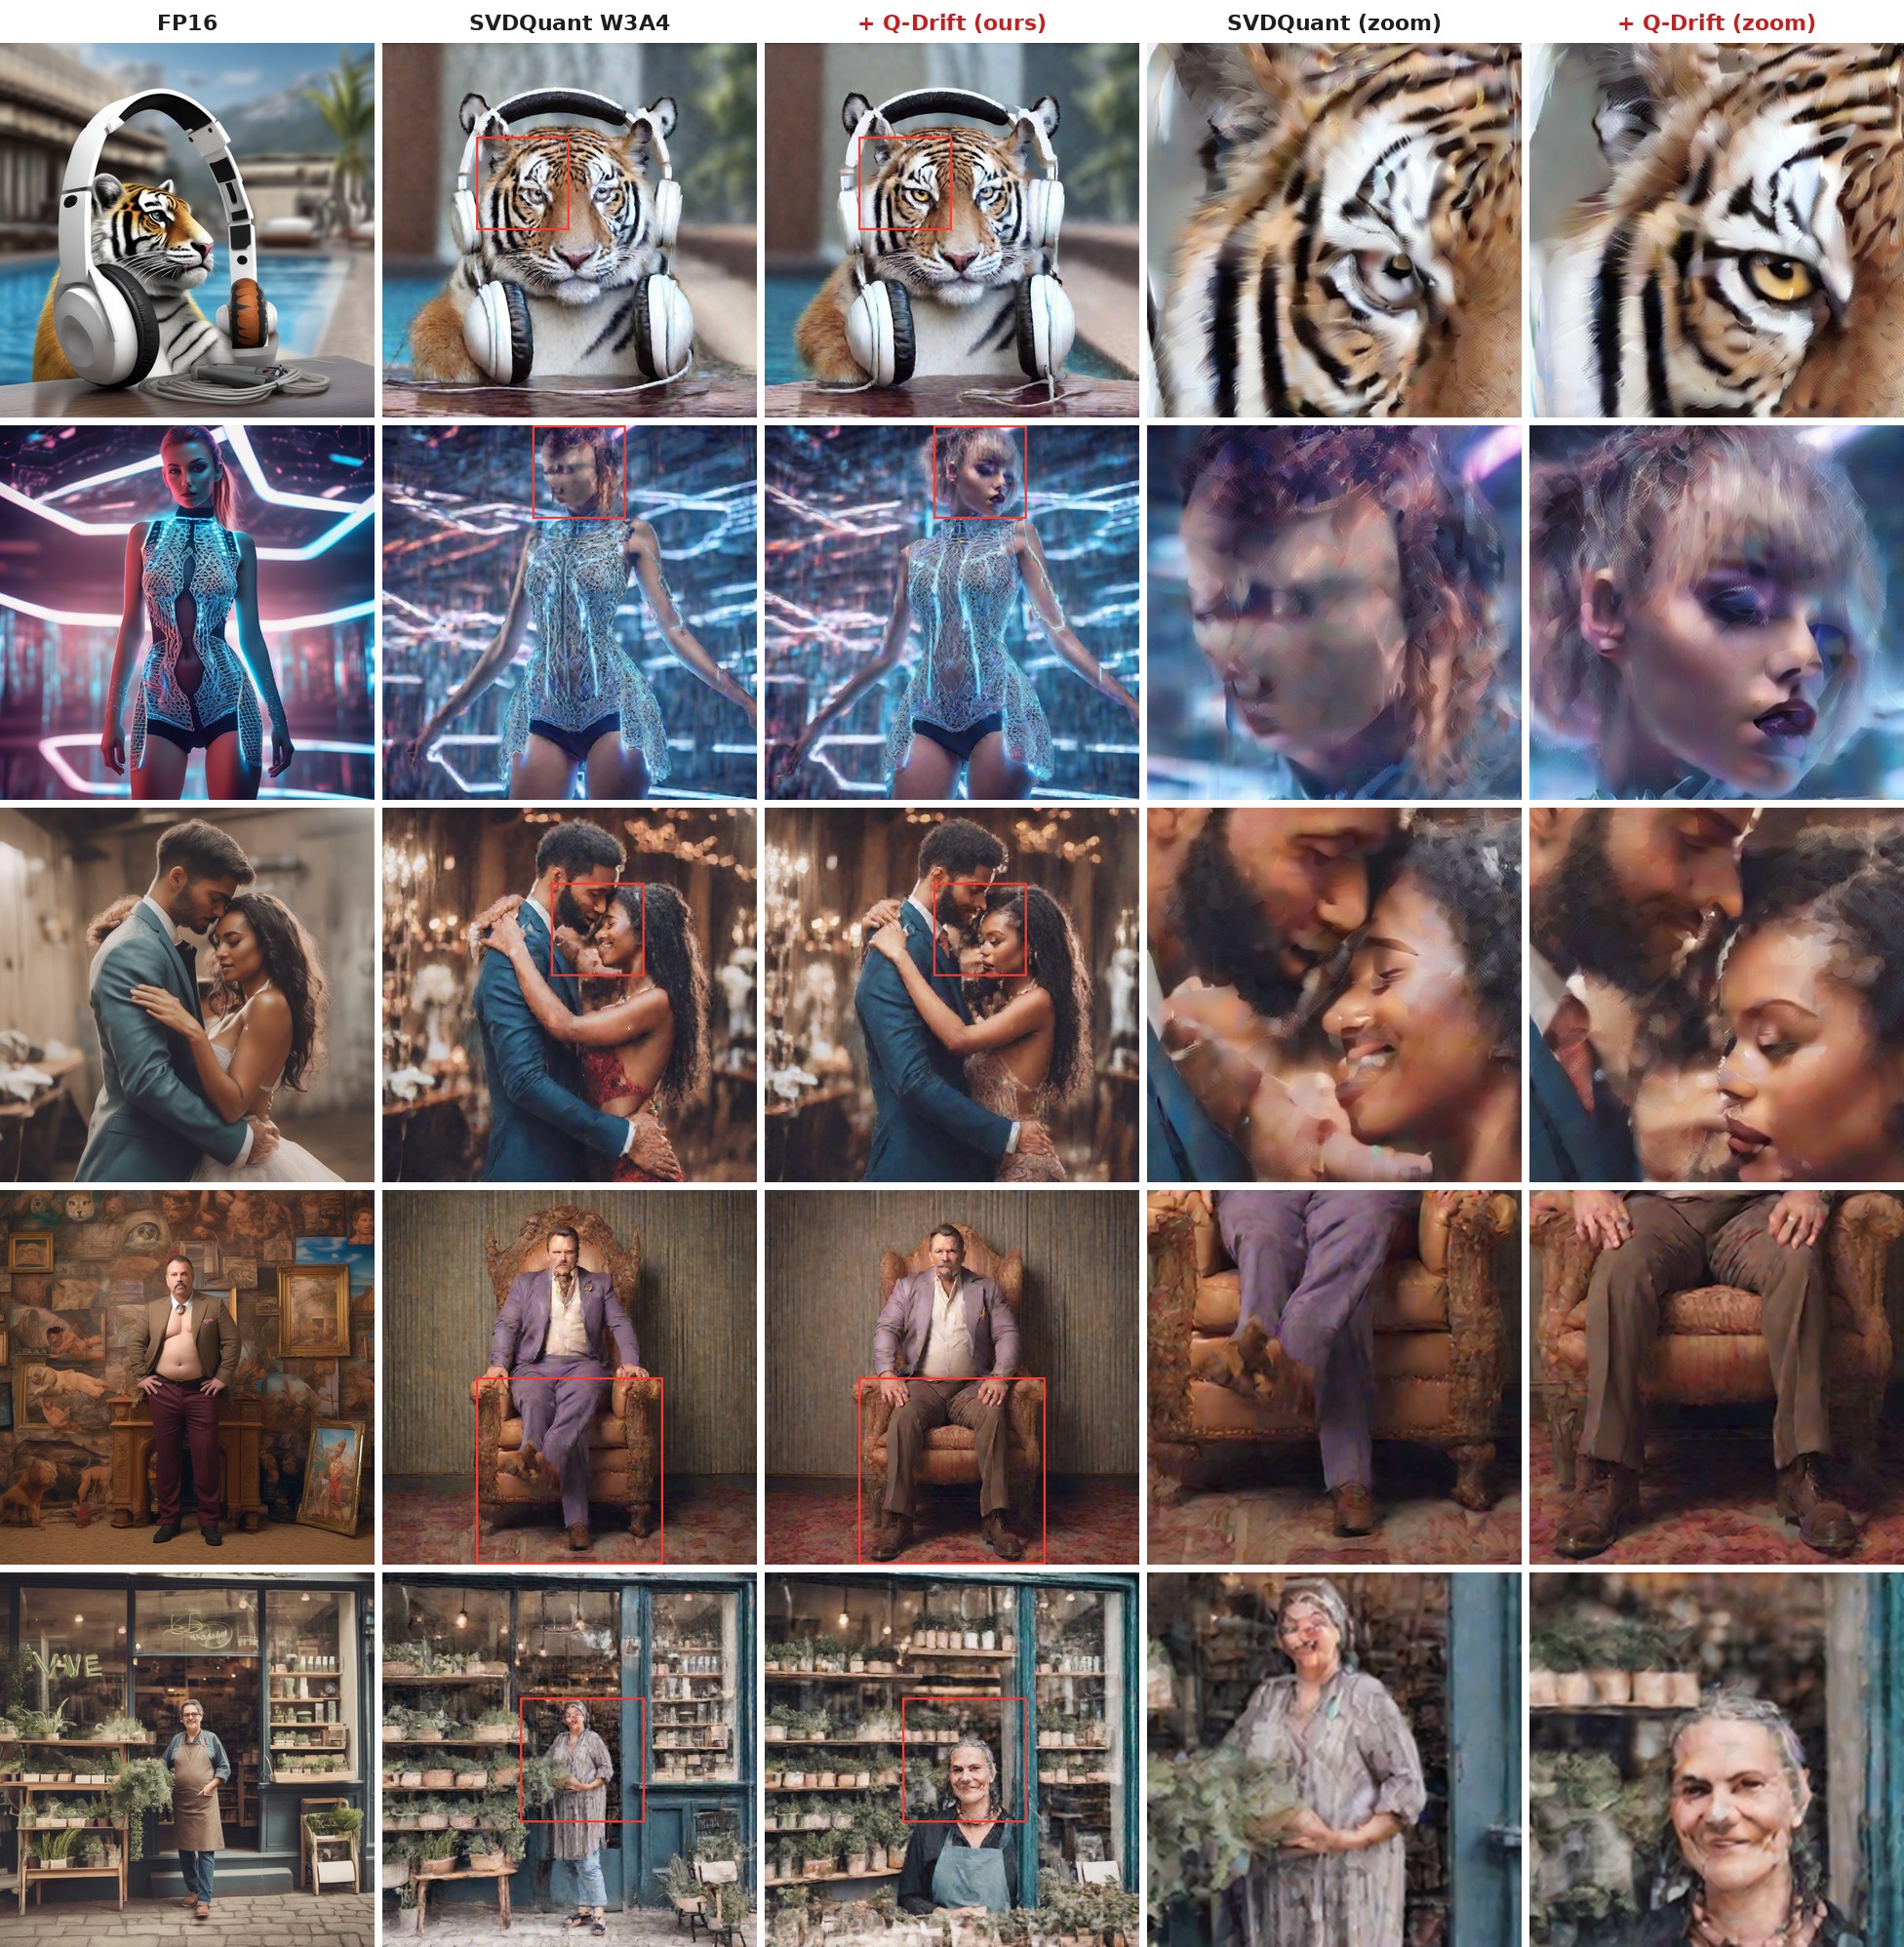
Q-Drift: Quantization-Aware Drift Correction for Diffusion Model Sampling
Sooyoung Ryu, Mathieu Salzmann, Saqib Javed Accepted at the NeurIPS 2026 BeNTo Workshop project page / arXiv / code / bibtex Q-Drift improves quantized diffusion sampling by calibrating one correction factor per step, without retraining or extra model evaluations. |
|
Website template by Jon Barron. |